Daimon Robotics builds the infrastructure layer for tactile intelligence
Credit: Daimon Robotics
Vision has become central to modern robotics, but cameras alone can’t tell a robot everything it needs to know about physical contact. When handling flexible objects, inserting components, or manipulating delicate objects, robots need information about forces, slip, and contact that visual systems may not capture.
Daimon Robotics wants to provide the infrastructure to help robots develop that ability.
Instead of focusing solely on touch sensors or developing a single core model, the company is building a pipeline that connects touch sensing, data collection, simulation, and artificial intelligence models. Its goal is to turn physical interactions into useful training data that helps robots perform manipulation tasks more reliably.
“By building haptic intelligence, we are effectively playing the role of an infrastructure provider,” said Zhu, partner and vice president of technology at Daimon The robot report. “We’re not aiming to become a commodity model developer. We’re providing the infrastructure to do that to downstream customers.”
This distinction is central to Daimon’s strategy: to develop the tools and data infrastructure that other companies can use to build more capable robotic systems.
Building a pipeline for tactile data
Collecting useful tactile data on a large scale is a challenge. Unlike visual data, which can be captured relatively easily with cameras, tactile data depends on physical contact. The resulting information varies based on the object’s material, geometry, forces applied, and task performed.
Daimon is developing a pipeline to capture and process these interactions, with haptic feedback operating at 30 Hz. The company is also working to connect real-world data with simulation, allowing physical interactions to inform training in virtual environments.
The gap between simulation and reality remains a significant challenge, particularly when accurately reproducing physical properties such as friction and contact forces. Daimon’s approach begins by calibrating simulations against real-world measurements before transferring the collected data into simulated environments.
“Let’s be honest; it’s not good enough. It’s pretty terrible,” Zhu said of the current state of the simulation, referring to the gap between simulated and real-world environments.
Daimon is developing tactile simulations that take into account physical properties measured through real-world testing. The goal is to improve the fidelity of such simulations and facilitate the transfer of learned capabilities to physical robots.
The company has discussed collecting over 10,000 hours of data, with its long-term Daimon-Infinity initiative aiming for over 1 million hours of embedded touch data.
Zhu also highlighted the importance of collaborating with companies developing robotic models and applications.
“Doing everything alone wasn’t enough,” he said. “Collaborating internationally in different downstream scenarios is really important.”
This collaboration helps Daimon understand what other developers need from its sensors, data collection devices, software and evaluation tools.
Credit: Daimon Robotics
From tactile demonstrations to industrial applications
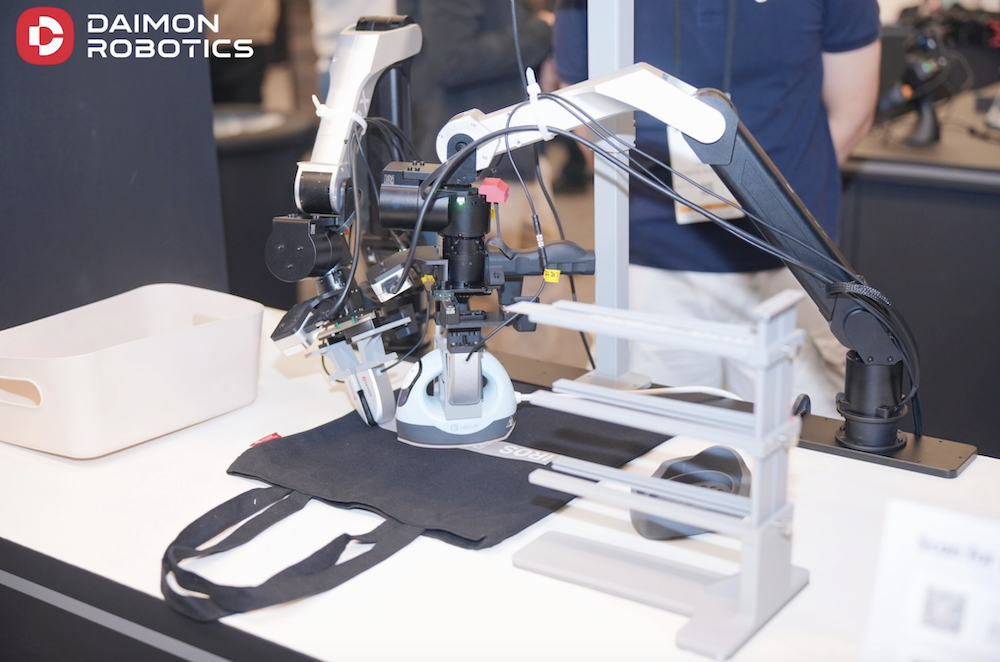
Daimon is focusing on manipulative tasks such as assembly and packaging, where robots must respond to physical contact rather than simply follow predetermined trajectories.
A robot may need to determine whether a component is positioned correctly, detect when an object slips, or adjust its movements when a part behaves unexpectedly. Tactile feedback can help him respond to these conditions.
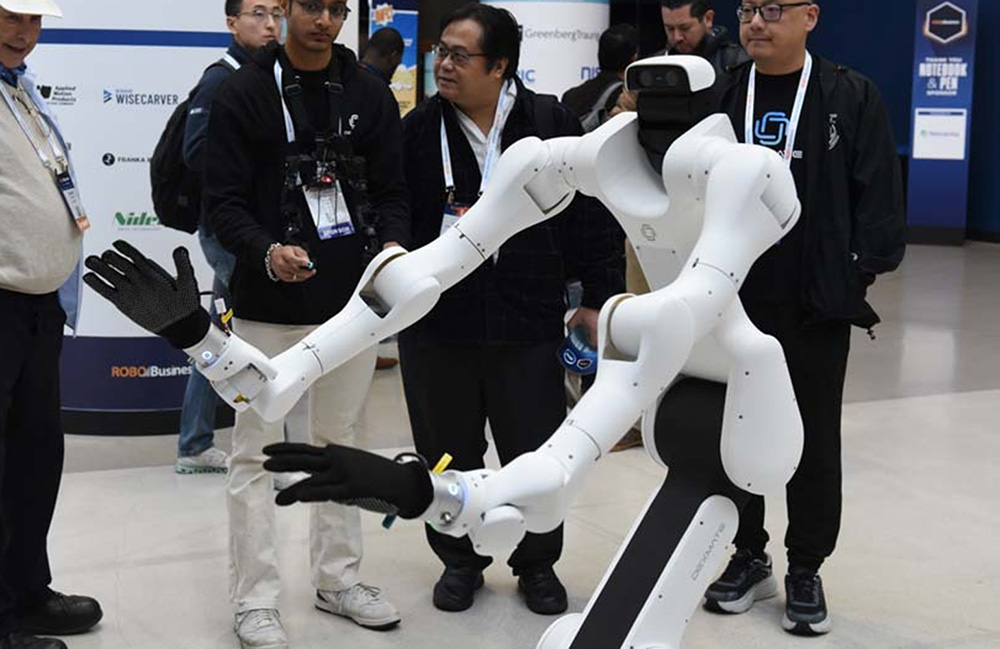
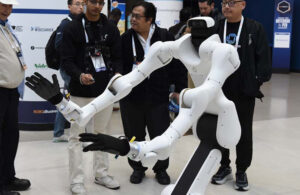
At IROS 2026, the company demonstrated applications involving delicate handling, including applying thermal transfer designs to threaded bags and bracelets. It also demonstrated a robot that collects and packages broken glass, illustrating how models trained on data from various scenarios can be tricked into performing specific tasks.
Daimon uses his Umi device to collect data from human interactions. Zhu said the company’s demonstrations were based on baseline models trained on data collected across multiple scenarios, rather than being built solely around demonstrations of individual robots.
The company has identified Lenovo Capital and Inovance Technology as key partners. Zhu said Daimon has moved beyond proof-of-concept projects in industrial assembly lines and warehouses, although he declined to name specific customers due to nondisclosure agreements.
The commercial test is whether tactile sensing and models built around it can consistently improve performance in manufacturing environments, where robots must handle variations in objects, materials and operating conditions.
Go beyond visual perception
Daimon’s broader strategy is focused on developing models that can use tactile information to understand and respond to physical interactions.
Its Daimon-TWM effort focuses on a tactile world model intended to help robots reason about physical interactions, rather than relying on visual perception alone.
Recognizing an object is only part of the manipulation. A robot must also understand how its actions affect that object and adapt when the physical outcome differs from expectations. Tactile feedback can help close this loop by providing information about contact and the consequences of an action.
Zhu described two roles of tactile sensing in robotic systems: helping models reason about physical properties and enabling rapid adjustments during contact-intensive tasks. The latter can require high-frequency feedback, with Daimon targeting control at 30 Hz.
The company is also exploring how data collected through human interactions can help train models for different robot configurations, including humanoids and dual-arm manipulators.
But data collection and training models are only part of the problem. Developers have yet to demonstrate that these systems generalize to different objects, materials, robots, and operating conditions.
Scalable touch for robotics
The broader question facing the robotics industry is what infrastructure is needed to reliably operate physical AI outside of controlled demonstrations.
Companies are investing heavily in vision-language-action models, simulation, and large-scale robot training datasets. Touch adds another dimension, particularly for robots that need to manipulate objects through physical contact.
Daimon aims to build part of the infrastructure that connects sensing, data, simulation and intelligence. Its strategy is to support companies developing robotic systems rather than compete directly with them to build the next general-purpose robotic brain.
Its success will depend on whether such an approach measurably improves manipulation, reduces the effort required to develop new applications, and supports implementation in diverse industrial environments.
Zhu was careful not to overestimate the capabilities of today’s models. Even when trained on large datasets, he said, their ability to generalize remains limited.
“The model is not as smart as we think,” Zhu said. “It has some ability to generalize, but sometimes it was a generalization within the domain.”
He added that embedded intelligence models are still being developed, and that collecting data from similar tasks can help them generalize to new applications.
For Daimon, the challenge is to translate this emerging capability into reliable performance across a broader range of real-world tasks.
Post Comment