Can AI agents program industrial robots without training data? Berkeley says yes
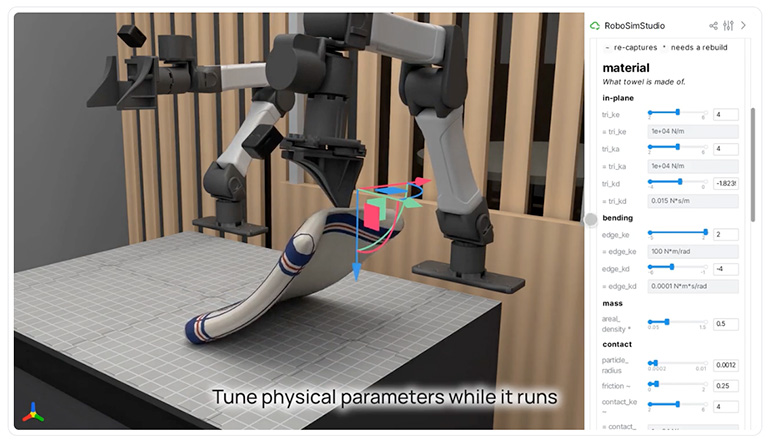
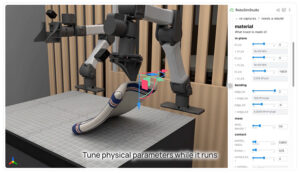
The new RoboSimStudio is an open source project that enables AI coding of robotic simulation environments. | Credit: UC Berkeley
UC Berkeley and NVIDIA have released open source tools for a new approach: enabling teams of AI coding agents to write, simulate, and refine human-readable robot programs.
Since the dawn of industrial robots, programming, tuning, and troubleshooting robotic work cells have taken weeks or months. New research led by UC Berkeley has shown that new AI programming tools could change the way industrial robots are coded and maintained.
Why is this important? As anyone who has programmed an industrial work cell knows, implementing the code must wait until the end of the design and manufacturing process. The robot must be installed in the work area; you also need to install all feeders, conveyors and other elements. The pressure to get this done falls on the software team, often as the project deadline approaches.
The new toolset goes beyond the idea of “coding the vibrations” of a robotic application. While it generates code with large language models (LLMs), what’s new is the use of AI agents to handle coding, testing, and deployment.
“Agentic robotics represents a fundamental shift in how robots are programmed,” said Ken Goldberg, William S. Floyd Jr. Distinguished Chair in Engineering at UC Berkeley. “Instead of collecting massive amounts of data and manually tuning each behavior, teams of agents can quickly generate, test, and refine robotic programs that allow human engineers to interpret how the programs work for tuning and verification.”
Researchers introduce GaP and VABAR
- Graph as Politics (GaP) it is a modular structure that divides a task into skills – perception, understanding, planning, collision-free movement – that agents generate, connect and test in the simulation.
- Variational Automation Benchmark for Agentic Robotics (VABAR) is a benchmark of six tasks: instrument sorting, instrument hanging, gear coupling, syringe packing, and cable insertion and routing. It is built on Isaac Lab-Arena and Newton, with standardized variations and difficulty levels.
- The UC Berkeley and NVIDIA team presented the concept at CoRL 2026 this week in Austin, Texas.
How the toolset works
Dr. Goldberg described the research The robot report. In September, Eric Chen, one of his graduate students, gave away GPT-6 Astra Eric’s new RoboSimStudio tool to see if it could generate not only a graphical model, but also a full 3D simulation of a scene. And this is exactly what happened.
According to Goldberg, Chen provided the model with a video and this new tool, and within an hour, a Newton simulation was generated that was incredibly similar to the video.
“When a new Frontier model came out in early September, they gave it the tool and a video,” Goldberg said. “Within about an hour, he produced a Newton simulation very similar to the video, through iterative trial and error.”
«And Newton [simulation] it’s really wonderful,” he added. “The problem is that Newton is very complicated. It has many parameters, hundreds of parameters. So, in general, people don’t use it much because it’s just too complicated, with too many knobs and switches.”
Goldberg praised Chen for putting this together. Initially, Chen built the instrument only for himself.
“I want my student Eric to get credit for this,” she said. “He basically sat down and created a new interface for Newton called RoboSimStudio. It’s basically just an interface that makes you have sliders on the right side of the screen and a viewer on the left. … You can adjust all these parameters much easier than before, so he built it just for himself to make the simulation part easier.”
But simulation alone is not enough, according to Goldberg. Simulation is important to the whole approach to using agents to code robots.
“The agent needs a simulator to be able to iterate and see how to improve this code,” he said. Goldberg noted that existing tools were “not very reliable and had a lot of problems.”
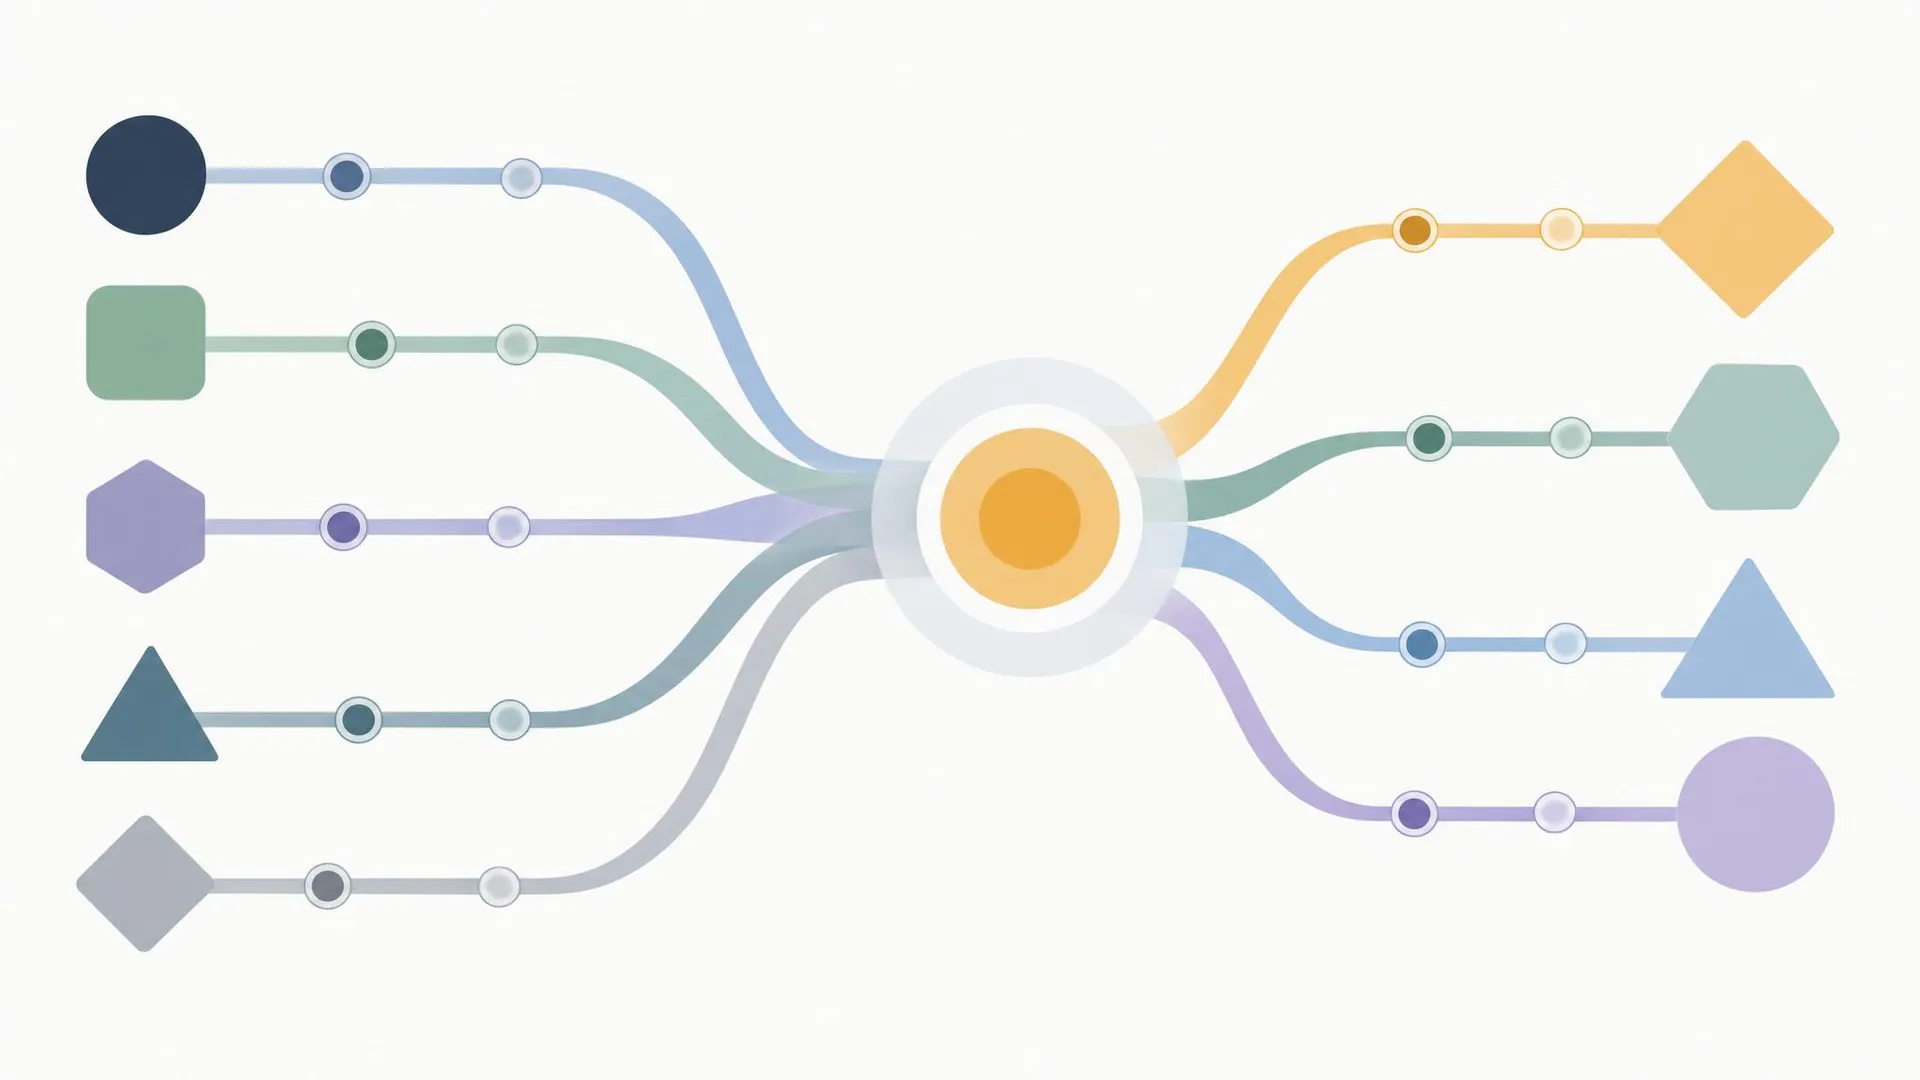
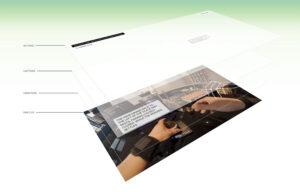
The harness converts a VA task specification into a computational graph, optimizes it via self-learning in the simulation, and delivers G* to an edge-based interpreter that guides the robot: simulation and real feedback close the loop. | Credit: UC Berkeley
Agents write and test code
Agentic robotics operates in a cycle: Agents write the robot’s code, test it in the simulation, see where it fails, and revise it. That circuit is only as good as the simulator behind it.
Newton Physics, UC Berkeley’s open-source physics engine of choice, is powerful but exposes hundreds of parameters, which has prevented many developers from using it.
RoboSim Studio made these parameters tractable, and this transformed the simulator from a bottleneck into something that an AI agent can tune on its own.
UC Berkeley developed the VABAR benchmark suite with the open source NVIDIA Isaac Lab-Arena policy evaluation framework and the Newton physics engine. Includes detailed physics-based simulation for contact-rich robot-object interactions.
VABAR evaluates how robots perform practical manipulation tasks ranging from sorting and moving tools to inserting and routing cables. The tool facilitates comparisons and measures progress across realistic industrial tasks, changing conditions and increasing levels of difficulty.
Each task includes standardized variations, difficulty levels, and success metrics, allowing researchers to measure progress, compare approaches, and evaluate whether systems can handle the demands of industrial operations. At the same time, Isaac Lab-Arena enables large-scale systematic evaluations under changing task conditions.
Spencer Huang, product director for robotics at NVIDIA (and son of CEO Jensen Huang), has been working with the Goldberg Lab at UC Berkeley to interface with NVIDIA product teams.
The partners listed some of the new features:
- Chart structure: Each node (perception, understanding, motion planning) can be assigned to its own agent, so that agents work in parallel without “getting in each other’s way”.
- ROS Equivalence: The graph is equivalent to a ROS graph and can be converted to ROS 2.
- Production: Python calling modules from existing vendors (such as KUKA) for low-level drive control. It does not replace robot controllers.
- The harness: Thousands of prompts and structures bind agents.
How do agents change robot programming?
When asked how this new approach differs from simply “coding the vibrations” of an app, Goldberg responded that the magic is in the harness GaP provides. The graph structure organizes the agents.
The code produced by “vibe coding” is already mature and well understood, he explained. The use of artificial intelligence to write code is accepted in software engineering today. But rarely does an application work as expected on the first pass.
This is true for software created by human engineers and is equally true for the development of software developed with artificial intelligence. Testing and iteration are necessary to optimize the application, Goldberg said.
When applied to robotics, the best practice now is to test in simulation before implementing the code on a real robot. With agent AI, a robotics engineer can allow the agent to iterate on both the simulation environment and subsequent code to more efficiently develop the robotic application.
For example, Bosch is evaluating agent-based robotics for various industrial automation scenarios. “Agentic robotics is very promising because it generates interpretable code that engineers can thoroughly analyze before deployment in production,” said Liu Ren, senior vice president and AI researcher at Bosch Research. “Bosch Research is actively collaborating with Goldberg and Huang and their teams.”
“AI-based industrial robots must continually improve reliability and performance,” said Jeff Mahler, co-founder and chief technology officer of Ambi Robotics. “Agent robotics converted production data into updates on robot behavior, increasing the productivity of our U.S. fleet and maintaining control over engineers.”
Goldberg is also a consultant for Ambi Robotics.
Propose your innovation now!
Post Comment