TIER IV Details Five open source models for autonomous driving – Unite.AI
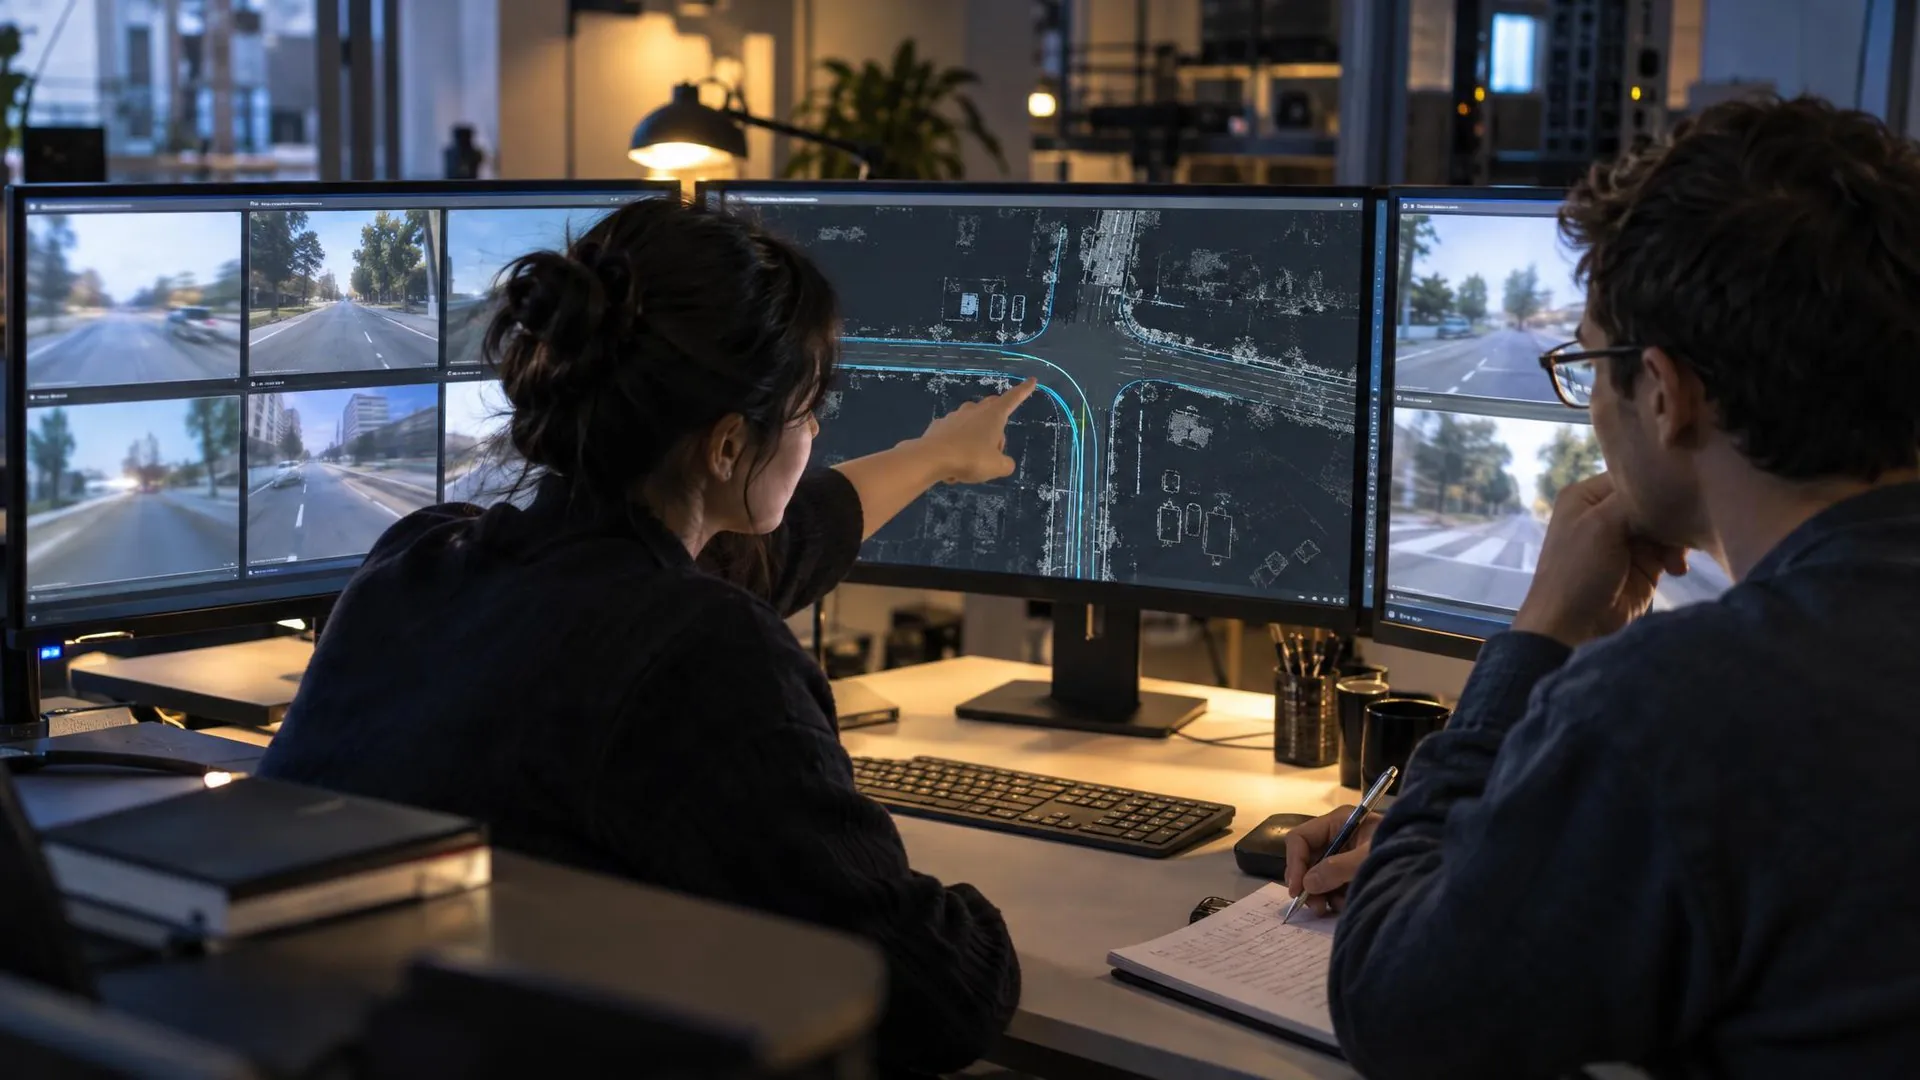
TIER IV announced on November 11, 2026 the development and open source availability of five end-to-end autonomous driving AI models for Autoware, including camera-only systems and configurations that add LiDAR, radar and high-definition maps. The range offers car manufacturers and technology partners various options for optimizing models and integrating them into vehicle systems.
The range includes NVIDIA Alpamayo 2 Edge, AutoE2E, METEOR, OnePlanner and LatentDrive. Their end-to-end designs link perception of the environment with driving trajectory generation, but the models differ in sensor requirements, planning approach and readiness: some are integrated with Autoware, while others continue vehicle adaptation or integration.
TIER IV presents the models as concrete technology deliverables for Autoware 2.0, the next-generation architecture detailed on November 2, 2026. That architecture combines artificial intelligence-based and conventional rules-based approaches, adds a flexible indexing scheme for modular software integration, and provides a reference design framework intended to facilitate commercial adoption across vehicles, applications, and operating environments.
Different models for different vehicles
TIER IV reports that Alpamayo 2 Edge has 2 billion parameters, compared to Alpamayo 2 Super’s 34 billion, and uses only camera imagery and reasoning to generate driving trajectories. The integration with Autoware is complete, but TIER IV is still optimizing the model and adapting it to real vehicles.
Autoware Foundation and TIER IV lead the development of AutoE2E. TIER IV pegs it at 79.9 million parameters and says it can run on computing platforms beyond NVIDIA hardware, with configurations ranging from just cameras to systems incorporating LiDAR and radar. Its fast-slow architecture combines a reactive model for real-time decisions with world and reasoning models that predict environmental changes and support driving decisions.
METEOR, developed independently of TIER IV and aimed primarily at privately owned passenger vehicles, has 16 million parameters. TIER IV says its convolutional neural network uses a bird’s eye representation to handle perception by generating trajectories in a single network without relying on HD maps. It accepts images from one to eight cameras, can add LiDAR and radar, and supports NVIDIA and Renesas semiconductor platforms.
TIER IV states that OnePlanner combines motion perception and planning. It currently uses BEVFusion to create a bird’s eye representation from LiDAR point clouds and transmits the features extracted during perception directly to the planner, reducing intermediate conversions in object positions and velocities. It also incorporates HD maps, route information, traffic sign states and vehicle movement states to generate six-second trajectories. Autoware integration is complete.
LatentDrive uses V-JEPA, a self-supervised learning approach, to represent camera video features in latent space and generate trajectories without intermediate object detection and tracking. TIER IV says it doesn’t require HD maps and produces four-second trajectories using video, route information and vehicle motion states. It supports one or three cameras, while Autoware integration and in-vehicle validation remain ongoing.
What AutoE2E V1.0 includes
The Autoware Foundation’s Robotaxi Working Group, sponsored by TIER IV, released AutoE2E v1.0 on November 11, 2026, under the Apache 2.0 License for research and commercial use, with trained checkpoints also available. The version includes the responsive model, which runs at 10Hz, merges views from six cameras into a bird’s eye view, and features 6.4 seconds of acceleration and steering. The world model and reasoning layers are still being developed to work with the same planner.
The foundation reports that the optimized AutoE2E model achieved an average displacement error of 0.744 meters over three seconds in validating recorded data, ranking second among eight open-weight configurations in its comparison. In that open-loop test, the patterns were predicted from the recorded frames of the cameras and were evaluated against the actual path of the human driver; AutoE2E also received a raster map and route, while inputs varied between models. The result therefore concerns the prediction of the trajectory on the recorded data, not the driverless road performance.
AutoE2E is integrated with Autoware for open-loop evaluation, and closed-loop testing is underway on real vehicles to evaluate interactive driving. The foundation says deployment performance and resource requirements remain subject to platform-specific evaluation, with further road trials planned for 2027. The project targets applications from L2++ hands-free driving assistance to future L4 driverless mobility, but L4 remains a development target rather than a current capability.
Commercialization and development workflow
For METEOR, TIER IV says it uses CoMET, the automated labeling platform within Co-MLOps, along with agent AI to automate data labeling and model training, evaluation and improvement, eliminating the need for manual coding and labeling. Automakers and component suppliers can optimize the open source model for their vehicle specifications and performance requirements.
Founder and CEO Shinpei Kato said the multi-model strategy is intended to help manufacturers and suppliers “internalize technologies based on their applications and performance requirements, without depending on a particular AI model or semiconductor platform.”
NVIDIA Automotive Vice President Ali Kani said the Alpamayo 2 Edge integration gives developers an open foundation to transfer technology from research to their vehicles.
The stated next steps of TIER IV are further performance improvements, vehicle optimization, commercialization with automakers and partners via Autoware, and expansion into all types of vehicles and applications. Autoware 2.0 provides the shared architecture, but incomplete closed-loop testing of AutoE2E shows that open source availability and validated vehicle implementation remain separate milestones.
Post Comment