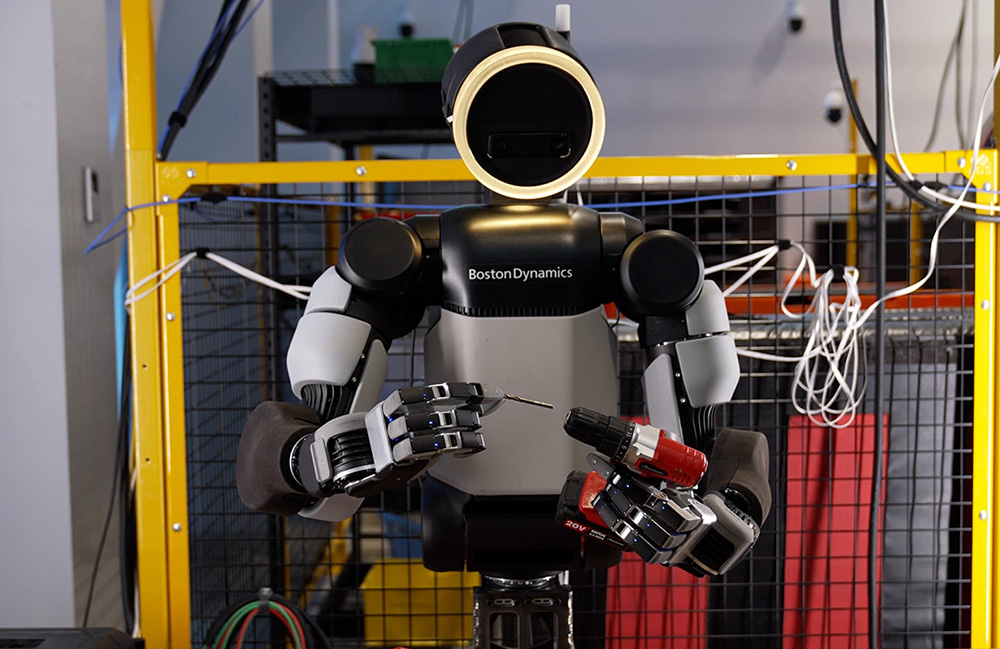
Boston Dynamics drops its pinky on the new humanoid hand
Boston Dynamics said it didn’t set out to build a complicated hand, but rather a reliable hand capable of using tools. | Source: Boston Dynamics
Boston Dynamics today unveiled the new hand for its humanoid Atlas. The hand has four fingers, 13 degrees of freedom (DOF), is directly operated, and is designed for mass production.
Previous versions of the Atlas hand featured seven degrees of freedom and were designed to grasp a wide variety of objects, Boston Dynamics said. With the latest twist, the company is shifting its focus to handling those objects.
“We looked at many, many designs, and there were a lot of questions like: Do we want the hand to have one thumb or two thumbs? Do we really want the hand to have a little finger or not? And most of those don’t have straight answers,” said Alberto Rodriguez, director of robot behavior for Atlas. “There’s always a certain amount of intuition and experimentation. It comes down to an exchange of different competing goals.”
Boston Dynamics said the four-fingered hand, which has no little finger, is built for high-fidelity simulation to enable sim-to-real (RL) reinforcement learning. The company said it has maintained transparent direct actuation on the joints, all with a single type of actuator. As in the Atlas body, these actuators are fully encapsulated, with no flimsy wires running through the joints.
The new hand is capable of:
- Slide the tip of your thumb along the length and width of all your other fingers
- The skillful pinch grabs between the thumb and any of the other fingers
- Skillful tripod grips
- Power tool sockets, such as drills, torque drivers, grinders, nail guns, and welding torches
The news comes just a week after Boston Dynamics opened its Robotics Metaplant Application Center (RMAC) at Hyundai Motor Group Metaplant America. The company said the facility in Georgia is a training center for integrating Atlas humanoids into parent company Hyundai’s automotive manufacturing operations.
Why is Boston Dynamics betting on four fingers?
When it comes to robotic hands, many companies are trying to recreate human-like hands as closely as possible. So why didn’t Boston Dynamics go down this path?
“There’s no pinky because the team determined that the dexterity and the additional tasks that you would be able to perform are not worth the additional complexity of three additional degrees of freedom, the size, the power consumption, all the things that come with adding additional actuators,” said Dylan Thrush, a mechanical engineer on the Atlas team.
Before the project was finished, Zachary Jackowski, product and technology manager at Boston Dynamics, asked the team to tape the pinky and ring fingers together for a day and report back on what they hadn’t been able to do. By the end of the experiment, the team had agreed that the robot hand didn’t need the little finger.
With four fingers and 13 DOF, the hand is able to reorient itself, recover from a slipped grip, and manipulate tools while squeezing triggers.
Size was also a big concern. A robotic hand needs to grasp objects of different sizes and potentially reach tight spaces. So it can’t be too big. Furthermore, hands that are more similar to human hands have a smaller cross-embodiment gap than human manipulation data.
Therefore, the new Atlas hand is similar in size to a large human hand, which significantly determines the size of the actuators. Thanks to several unique actuation technologies, the company said it maintained similar strength to the previous hand.
Retro-drivability and transparency of the actuators are central to the design philosophy of the entire robot, Boston Dynamics said. It allows the company to rely on proprioception for agile and agile behaviors. Complementary to proprioception, Boston Dynamics has equipped the hand with dense tactile pressure sensors covering the fingertips and palm that allow it to pick up small contact signals.
Building a hand for simulated learning
Atlas’ thumb features four DOFs, while the other three features have three DOFs each. | Source: Boston Dynamics
Some of today’s best options for scaling data collection for manipulation involve universal manipulation interfaces (UMIs). With these wearable devices, demonstrators perform tasks naturally, while sensors capture the most relevant signals during manipulation, such as contact events and pressure distribution.
Direct imitation has its limits, however, something Boston Dynamics said it has mastered when it comes to full-body humanoid control. Whole-body behavior for a humanoid is always implemented on top of a whole-body controller that takes care of the high-speed dynamics of behaviors such as balance, recovery steps when stumbling, and compensation of forces such as gravity, self-collisions, or external pushes. Importantly, today these full-body controllers are always trained with RL in simulation.
Boston Dynamics said human demonstrations are best suited to capturing the visual complexities of a situation. But, fundamentally, skillful and fast manipulation is also a byproduct of closed-loop control and high-speed force regulation. This is something that wearables don’t capture. Therefore, the company believes that RL in simulation is an essential component to solving skillful manipulation.
This had a big impact on the design of the hand. Boston Dynamics has claimed, in many ways, to have created the hand for the sim2real and RL transfer. The implementation of the rigid drive and backdriver transmission, together with the innovation of controls to compensate for cogging and friction, allow the hand to be simulated with high dynamic fidelity.
This fidelity in turn makes RL more effective at training robust control policies with exposure to randomizations of motor torque profiles, surface friction coefficients, object geometries, and task disturbances.
The company has early results showing promising sim2real transfer to dynamic tasks. These behaviors are trained directly in simulation with domain randomization and implemented in hardware relying only on high-speed actuator proprioception for feedback.
Editor’s Note: Brendan Schulman, vice president of policy and government relations at Boston Dynamics, will participate in a panel on “Reshoring With Robots: A Policy Discussion” at RoboBusiness 2026, taking place October 20-21 in Santa Clara, California. Register now to participate.
Register now and help us celebrate 20 years of RoboBusiness!

Post Comment