Because dexterity is the real bottleneck of physical AI
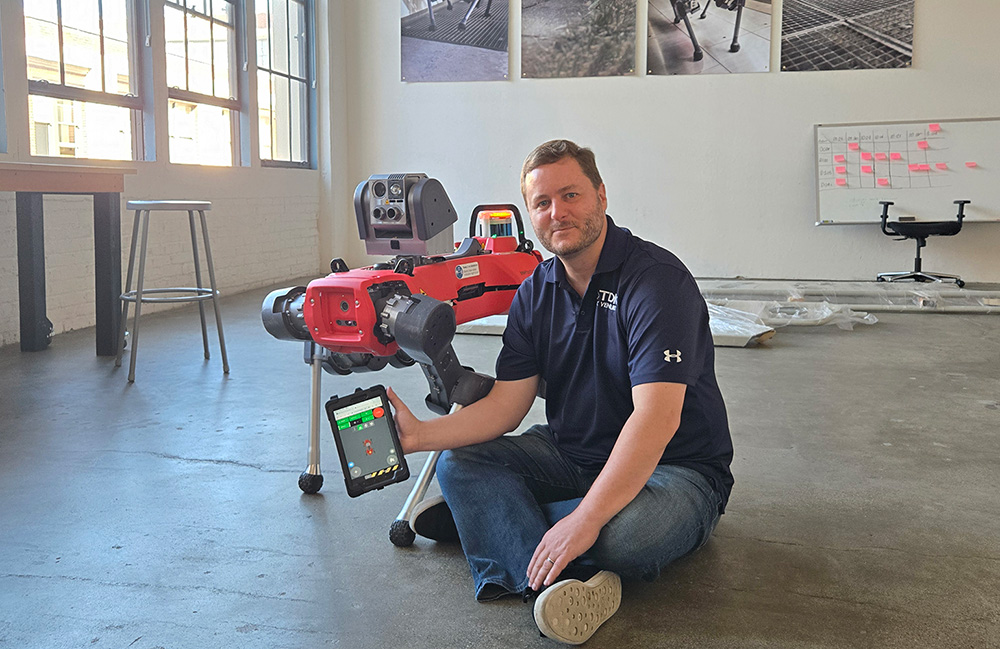
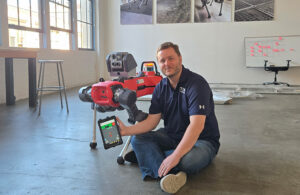
Nicolas Sauvage, founder and president of TDK Ventures, with the ANYbotics quadruped robot. | Source: TDK Ventures
A robot picks up an object, moves it and deposits it successfully. Is he skilled? Perhaps. But now ask him to do this successfully hundreds of times, as objects move slightly, his grip changes, components wear out, and unexpected failures occur. This is a much more difficult dexterity test and a much better measure of whether a robot is skilled enough for the real world.
We are making rapid progress in what robots can manipulate. However, useful dexterity is not simply the ability to complete an individual action once. It is the ability to sense, grasp, move, adjust, and retrieve reliably enough to complete an entire workflow without constant human assistance.
A robot that succeeds 99% of the time appears ready for the job, but a job rarely consists of a single action. Consider a workflow that requires 100 physical actions in sequence. With a 99% success rate for each action, the probability that all 100 will succeed on the first try is only 36.6%. It increases the success rate to 99.9% and the probability of completing the workflow increases to 90.5%. At 99.99%, you reach 99.0%.
This is, of course, a simplified example that assumes equal and independent success rates, but it illustrates an important point. A robot with a 99% success rate is not necessarily 99% automated.
Small gaps in reliability become much larger when repeated across an entire workflow. This means that a robot that looks almost flawless in a demonstration may still be far from ready for autonomous deployment. The difference between two nines and four nines can ultimately decide whether a robot is ready to work alone.
The next big challenge in robotics prowess is not simply teaching robots to do more, but making the entire system reliable enough to turn those skills into useful work.
Dexterity is a system, not a hand
Robotic dexterity is often discussed as a hardware race: more fingers, more joints, and more freedom of movement. While such capabilities are obviously important, the client gains no degrees of freedom. The customer buys useful work.
Completing this work requires a closed loop between vision, position, contact, force, pressure, grip, movement and adjustment. Power, safety, flexibility and recovery also matter.
Not all workflows require touch, as in some cases vision and motion data can provide sufficient information. But touch can also be useful for telling a robot that an object is slipping, that the contact is unstable, that too much pressure is being applied, or that a component is correctly positioned.
The goal is therefore not to accumulate all the senses in each robot, but to provide the system with enough right information to act and recover reliably.
TDK Ventures helps early-stage materials, energy, cleantech, industry 5.0, mobility and healthtech startups grow. | Source: TDK Ventures
Another nine come from learning
Recovery is an important part of dexterity. If a robot starts to lose its grip on an object, the useful measurement is not whether the original grip was perfect; the question is whether the system can detect the error early enough to correct it before a small error causes the entire task to fail.
An error discovered during deployment could expose a problem in software, detection, or control, or it could reveal that the hardware itself needs a redesign. Changing hands changes movement, sensing, and calibration, so data collected with one physical design may not transfer directly to another. Real-world implementation is therefore a key part of the development process.
Implementation reveals slips, poor grip, wear and failed recoveries. These experiences become data that can improve software, simulation, sensing, control and hardware. Each cycle can make the next deployment more reliable and less expensive.
A technological breakthrough may start the journey, but it is the learning system around it that multiplies its impact. Robotic dexterity should be viewed in much the same way. An additional nine emerge from repeated implementation, learning, and improvement.
Editor’s Note: Physical AI, enabling technologies and humanoids are among the topics of the RoboBusiness 2026 session, which will be held on October 20 and 21 in Santa Clara, California. Register now to participate.
Register now and help us celebrate 20 years of RoboBusiness!
The right body depends on the job
Trustworthiness also requires us to resist the temptation to equate more human-like robots with better robots. The starting point should be work. From there, work backwards to determine the environment, fitness, and system required to perform it.
Dexterity should follow the same logic. The most human-like hand may not be the best hand for a particular workflow. The goal is not maximum dexterity. It’s the minimum sufficient dexterity needed to complete valuable work reliably, and we’re already starting to see this principle being implemented successfully.
That of agility Digit is a bipedal robot designed for logistics and industrial work. Digit can connect directly to specialized tools suited to the job, rather than requiring a five-fingered hand or being made to look as human as possible. It has the shape and dexterity that the job actually requires.
ANYbotics applies the same principle to a different environment. Its four-legged robots can navigate stairs and uneven surfaces in industrial sites, while inspecting hazardous areas reduces the need for human exposure. In one deployment, its technology would accomplish more than 33,000 inspections out of 450 inspection points.
Starship Technologies takes a different approach. Its delivery robots must travel along sidewalks, so a small wheeled form is better suited to the job than legs. This targeted approach has helped Starship report more than 10 million autonomous deliveries.
These robots look and function very differently because they do very different jobs. Yet they demonstrate the same principle: the right physical form is one that is suited to the job and can perform it repeatedly in the real environment.
Our investments in Agility, ANYbotics, and Starship have changed the questions I ask as an investor, particularly as we continue to deeply explore Dexterity. I’m less interested in which robot feels more human than in which complete system can achieve the reliability the customer actually requires.
Sauvage with the humanoid robot Digit by Agility Robotics. | Source: TDK Ventures
Measure the work, not the demonstration
This changes how we should measure progress in physical AI. The success rate of an individual action shown in a demonstration tells us very little about whether a robot is actually ready to work autonomously in the real world.
I want to know what percentage of complete workflows finish without human assistance. When something goes wrong, how often can the robot recover without help? How does performance change as the object, lighting, position, wear or surrounding environment changes?
Then there are the less glamorous issues that become extremely important on a large scale. What breaks first if used repeatedly? How quickly can it be diagnosed, repaired and returned to work? What is the speed, uptime and cost of each successfully completed job?
Ultimately, these are better measures of dexterity than a robot can once demonstrate. A robot does not need the most human-like hand, the most joints, or the widest possible range of skills to create value. It needs the right combination of fitness, sensitivity, control and recovery to complete valuable work reliably in the environment in which it will actually work.
This is where I believe the next phase of advancement in robotics prowess will be won. The industry has made extraordinary progress in what robots are capable of doing. Now the challenge is to turn these capabilities into systems that customers can trust to repeatedly perform useful work, recover when something goes wrong, and improve through deployment.
About the author
Nicolas Sauvage is the founder and president of TDK Ventures, the global venture capital arm of TDK Corp. He launched the company in 2019 around a simple principle: entrepreneurs come first.
Today, TDK Ventures manages $500 million across four funds and supports early-stage startups globally, across AI and computing, energy, industrials and robotics, mobility and advanced materials.
Post Comment