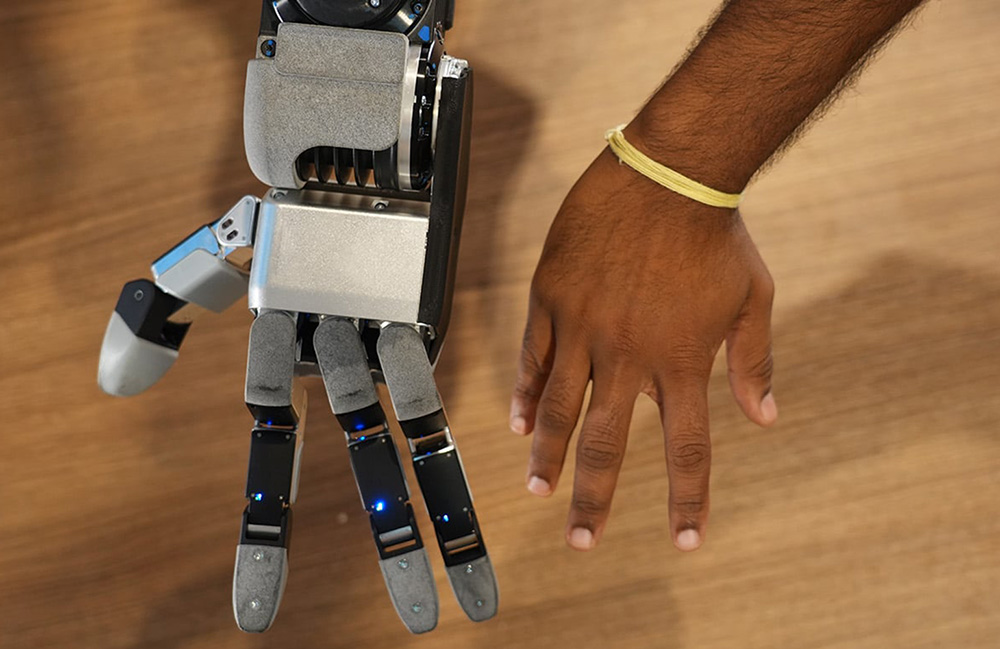
Boston Dynamics provides more information on its redesigned humanoid hand
Boston Dynamics said its new hand can still handle over 100 pounds. | Source: Boston Dynamics
Last week, Boston Dynamics Inc. gave a look at its new humanoid robotic hand. The four-fingered hand has 13 degrees of freedom, or DoF, and is directly actuated. The company said it designed it for mass production.
Many things stand out immediately in the hand. Most notably, Boston Dynamics ditched the pinky and reduced the size of the gripper. Less obviously, the company said it built the new hand for high-fidelity simulation to enable sim-to-real (RL) reinforcement learning.
To learn more about the new hand, The robot report spoke with Alberto Rodriguez, the director of robot behavior for Atlas at Boston Dynamics.
What did Boston Dynamics learn from its experiments on humanoids to apply to the new hand?
Rodriguez: Having a product roadmap for Atlas was a key factor when it came to making tough decisions like what was the right level of complexity we should hold and managing the design trade-off between dexterity, strength, robustness, cost, repairability and sensitivity.
We learned a few things from the Atlas’ body design. There are things like simplicity, modularity and maturity of actuators that make sense in theory, but over time you start to appreciate the huge impact they have on how fast you can move.
A reliable robot allows you to acquire data faster, run more experiments and bet on initial implementations. Modularity allows you to focus more energetically on fewer things you need to do well. This also allows you to move faster.
We used the same philosophy with this hand. It consists of 13 identical actuators, all fully encapsulated, with no flimsy wires running through the joints, which is already paying off.
We also learned, for example, that previous hands were strong enough to lift heavy objects over 100 pounds, so we did not need to increase the strength and could consider decreasing it slightly to further improve the transparency of the actuation. We also experienced the challenges that previous hands had faced with some more complex tasks, which influenced the current design.
Have you looked at any standard end effectors and why did you decide to build one in-house?
Rodriguez: We always look at what’s out there to understand the state of the art. Hands are a key element of technology, so integral to the value proposition of humanoids that it would be very difficult for us to address it in any other way than internally.
As we described in our blog articleall hands come from a very consequential trade-off of capabilities and understanding how it fits into the product roadmap is critical.
How does Boston Dynamics ensure durability so the gripper can last for many shifts?
Rodriguez: This is not very different from how we do it for other key technologies in the robot.
It all starts with an amazing hardware design team that has done this many times before and has developed the intuition of what leads to reliable hardware.
We also have a strong culture of collaboration between the behavioral and hardware teams in those early design phases to lock in key design features, such as morphology, sensing, torque distribution, etc., using techniques such as simulation or model design. This allows the hardware team to approach detailed design with greater confidence.
We build the first prototypes and put them in the hands of the systems, controls and behavior teams for a while to unearth as many unknown unknowns as possible and iterate on the design.
We then subject the hands and their various subcomponents to rigorous validation and verification tests to ensure that they perform as expected. While this is tedious and may initially slow down the implementation of new hardware, it ends up speeding up the process by allowing you to refine problems faster than having to laboriously discover them in the field.
What kind of tasks did you test with the new hand?
Rodriguez: All kinds. It is difficult to define the requirements of a complex system like a hand, and one way to do this is to construct a set of tasks representative of what the hand will need to do in the future. Many of these are common industrial tasks such as using portable power tools, handling cables, and fishing for screws.
We’ve also used these hands in many less mission-oriented tasks, such as training tasks that we use to compare with previous hands, and in other tasks that help us explore the limits of what the hands are capable of.
As always, we like to take inspiration from human physical feats, like parkour or gymnastics, to push ourselves and do it in a way that connects with people. We played with different types of juggling and speed games with our hands.
Boston Dynamics said it didn’t set out to build a complicated hand, but rather a reliable hand capable of using tools. | Source: Boston Dynamics
Can you tell us more about Boston Dynamics’ process that decides how many fingers to include in the hand?
Rodriguez: The process is based on intuition, on periods of high entropy in conceptual designs, and then on a set of tasks or behaviors that we wanted the hand to be able to perform. Our product roadmap gives us concrete manipulation tasks that we know are within the scope of Atlas.
Using tools is one important example, but there are many others, from how small screws Atlas should be able to pick out to how small spaces Atlas should be able to get his hands into.
Another useful way to identify hand requirements is as a set of movements important for skillful manipulative behavior and measure projects against them. Here are some of the key movements we focused on:
- Be able to slide the tip of your thumb along the length of your other fingers
- Be able to slide the tip of your thumb over your fingers
- Be able to swing the tip of the thumb against the index finger in a deft grip
- Be able to exert powerful grips on activated tool handles
Decisions such as the number of fingers or the number of joints per finger are difficult, but we try to maintain a pragmatic perspective and a clear vision on factors such as cost and reliability which are key to being able to expand production.
For example, one drawing that had a lot of initial support was a hand with two thumbs, one on each side. This design had the added advantage of not having to have separate left and right hands. You can make them on a single assembly line.
We ultimately decided not to do this because it involves additional implementation complexity which ultimately resulted in additional DdF, cost and volume.
What about the hand makes it easier to work in simulation and reinforcement learning?
Rodriguez: We design the actuation and transmission with an eye to rear-driveability and transparency. From a controls perspective, we have developed techniques to compensate for some of the remaining non-idealities on the actuators, such as compensating for different types of friction.
All this allows for accurate dynamic simulation, which is fundamental to the design philosophy of the entire robot. This makes reinforcement learning more effective in training policies that can use proprioception, where the actuators themselves sense that you are repelling them and transfer them directly to the hardware.
This is the exact same recipe that has been successful in recent years for the agile behavior of humanoids. Build actuators that simulate well and then rely on large-scale RL.
I am convinced that the ability to use RL in simulation will be a key factor in the next generation of manipulative capabilities for complex skills, going beyond pick and place. These are difficult tasks to telemanage or demonstrate, because much of the information relevant to reproducing them is found in rapid changes in contact distribution and pressure.
Have you started testing the hand at RMAC and what have been the results so far?
Rodriguez: Not yet. We have used the new hands extensively at our site, but have not yet implemented them across our entire robot fleet. This is a process that requires coordination and time to ensure it does not disrupt regular operations such as data collection or applications.
Editor’s Note: Brendan Schulman, vice president of policy and government relations at Boston Dynamics, will participate in a panel on “Reshoring With Robots: A Policy Discussion” at RoboBusiness 2026, taking place October 20-21 in Santa Clara, California. Register now to participate.
Register now and help us celebrate 20 years of RoboBusiness!

Post Comment