Runway presents the Praxis-1 world action model for robotics
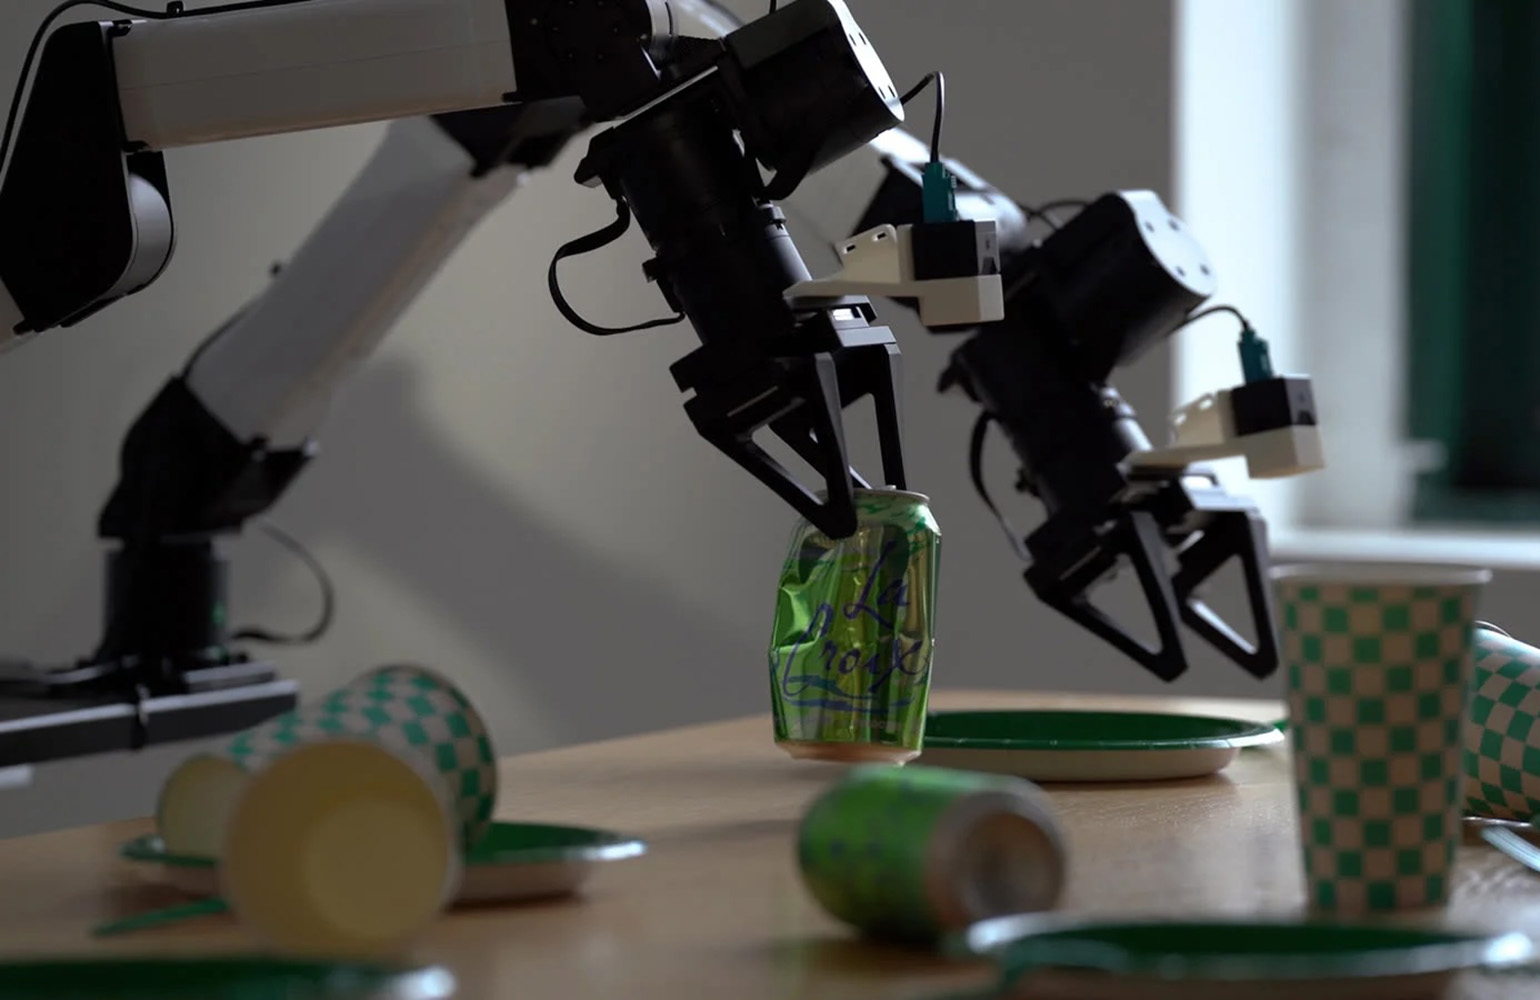
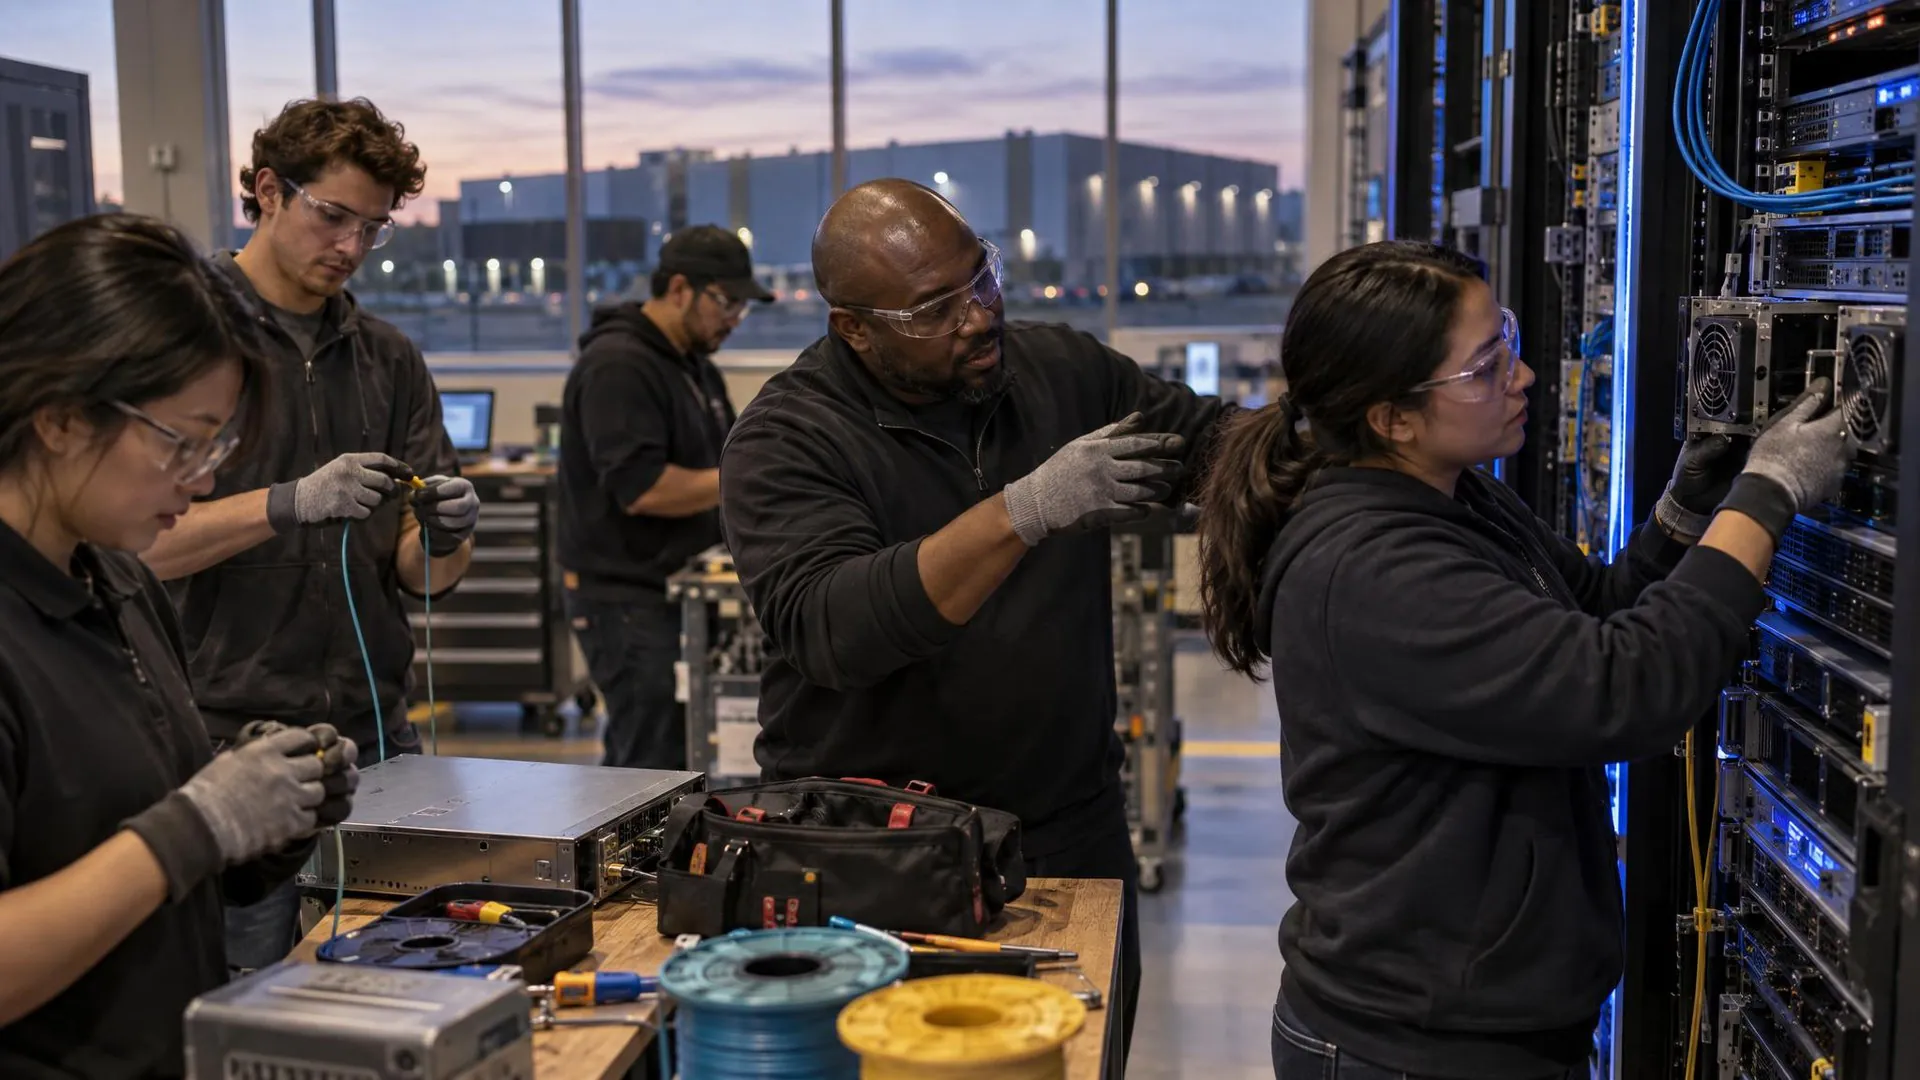
Runway said it is testing Praxis-1 across a variety of embodiments and environments to identify and fill potential gaps before moving to general availability. | Source: track
Runway AI Inc. this week introduced Praxis-1, an open-weight world action model that turns Runway’s video pre-training into control for robots. The company said it built Praxis-1 on the same large-scale video pretraining that underpins its general world models.
“Most robot policies are hampered by robot data, which is scarce and expensive to collect,” said Kamil Sindi, Runway’s chief technology officer. The robot report. “Praxis-1 learns primarily from third-person videos, based on the same large-scale pre-training that underpins Runway’s world models, so it already understands how objects behave and how tasks perform.
“Also, performance improves as you scale the video, so its limit is set by how much video it can learn from, not how many robot demonstrations exist,” he added.
Founded in 2018, Runway AI specializes in generative artificial intelligence research and technologies. The company offers a range of AI models, including Aleph 2.0 for in-context video editing, Act-Two for motion capture, and Gen-4.5 for text-to-video and image-to-video generation.
For robotics, Runway also offers the GWM-1, a general world model. The Brooklyn, New York-based company has offices in New York, San Francisco, Seattle, London, Paris, Tel Aviv and Tokyo.
Runway has tested Praxis-1 with early partners and plans to release the model publicly in the coming months.
Editor’s Note: Physical AI is one of the topics covered in the RoboBusiness 2026 session, which will be held on October 20 and 21 in Santa Clara, California. Register now to participate.
Register now and help us celebrate 20 years of RoboBusiness!
Bets on the catwalk on video data for robot training
While there is a lack of real-world robotics data to train generalist AI models, video data abounds. Every day, people film and upload more moments of daily life than any robotic lab could capture through teleoperated demonstrations, Runway AI noted.
Runway found that simulating robot policies within its world model predicts real-world outcomes with a correlation of 0.95. This compares favorably with more expensive 3D reconstruction-based techniques, the company said.
Additionally, Runway has extended its work pre-training large video models into real-time interactive video models like Solaris and GWM Worlds 2. By teaching models how to generate accurate physics, how hands move, what a halfway task looks like, the company said it has created dynamic, complex environments for training agents in the digital and physical world.
Runway said Praxis-1 brings the same approach to robotics, providing a generalist policy model for robotics developers and researchers that works in any incarnation or environment.
“Praxis-1 was trained on a variety of manipulation tasks, ranging from simple pick-and-place actions, such as lifting soda cans, to more complex tasks involving deformable objects, such as packing gift bags,” Sindi said.
Praxis-1 is already in the testing phase with the first partners
Runway is distributing Praxis-1 to key partners ahead of public launch. The company also hopes to provide access to additional partners before launch. Runway plans to evaluate its model on a variety of robots.
“Early partners, including Noble Machines, Standard Bots and Ultra, are running Praxis-1 on their own hardware,” Sindi said. “One important takeaway so far is that a single model can accommodate very different embodiments, from bimanual arms to humanoids, with a little fine-tuning. Their testing is helping us identify and fill gaps ahead of general availability.”
When Runway publicly releases the Praxis-1, it plans to ship it with open weights rather than as a closed model.
“We believe that U.S. leadership in physical AI is critical to regaining our leadership in manufacturing, and that requires open American models,” Sindi said. “Open weights give hardware developers flexibility and control they don’t have today.”
Looking ahead, the company hopes to pre-launch with more select partners to continue improving its model before its full launch.
“We will continue to test and evaluate Praxis-1 with partners, engage more early access partners, and evaluate efficacy and safety in different embodiments and environments,” Sindi said.
Runway says that a policy that already understands physical plausibility and object behavior from video pre-training has a huge advantage over a policy built solely on action data. | Source: track
Post Comment